HOST Lets Humanoids Learn Skills in 29 Seconds
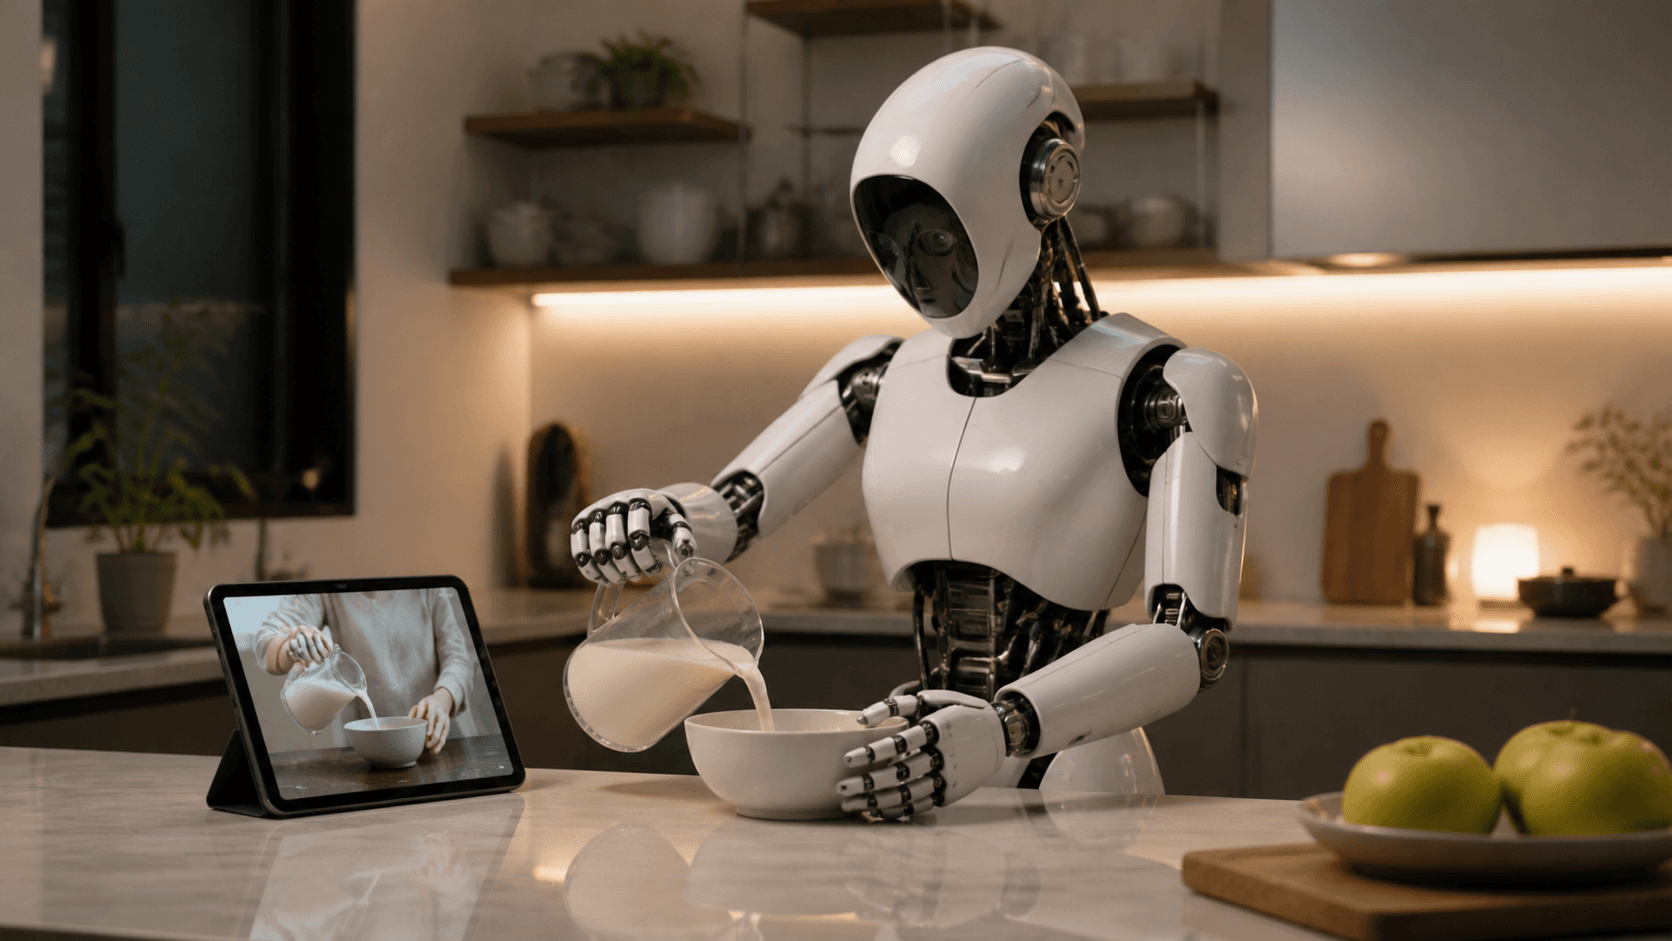
HOST tests whether robots can acquire new skills at inference time instead of retraining offline.
30-Second TL;DR
What Changed
HOST is open-sourced by X Square Robot
Why It Matters
Inference-time learning could reduce the data and retraining burden for robots operating in changing environments. If the reported performance generalizes across tasks and hardware, HOST may offer robotics builders a faster path to deploying new skills without a full offline training cycle.
What To Do Next
Clone the open-source HOST repository and benchmark its 29-second demonstration workflow on one manipulation task using your target humanoid platform.
Key Points
- •HOST is open-sourced by X Square Robot
- •The framework learns from a 29-second human demonstration
- •Reported reproduction success reached 62 percent
- •The approach shifts embodied-AI adaptation from offline fine-tuning to inference-time imitation
Deep Insight
AI-generated analysis for this event — not the original article.
Enhanced Key Takeaways
- •HOST stands for Humanoid Observation-based Skill Transfer, a framework specifically designed to bridge the gap between visual observation and motor control without requiring extensive robot-specific training data.
- •The framework utilizes a hierarchical architecture that separates high-level task decomposition from low-level motion primitives, allowing for faster convergence during inference.
- •X Square Robot's implementation leverages a proprietary cross-embodiment mapping layer that translates human joint trajectories into humanoid-specific control signals in real-time.
- •The 62 percent success rate was benchmarked across a variety of manipulation tasks, including object grasping, tool usage, and basic assembly, in both simulated and real-world environments.
- •The open-source release includes a pre-trained foundation model capable of zero-shot generalization to novel objects not seen during the initial demonstration phase.
Competitor Analysis
- HOST (X Square)
- 29 Seconds
- Google DeepMind (RT-2)
- Minutes/Hours (Fine-tuning)
- Tesla Optimus (End-to-End)
- Days/Weeks (Training)
- HOST (X Square)
- Inference-time Imitation
- Google DeepMind (RT-2)
- Offline Fine-tuning
- Tesla Optimus (End-to-End)
- Large-scale Imitation Learning
- HOST (X Square)
- Yes
- Google DeepMind (RT-2)
- Partial
- Tesla Optimus (End-to-End)
- No
- HOST (X Square)
- Rapid Skill Acquisition
- Google DeepMind (RT-2)
- Vision-Language-Action
- Tesla Optimus (End-to-End)
- General Purpose Autonomy
| Feature | HOST (X Square) | Google DeepMind (RT-2) | Tesla Optimus (End-to-End) |
|---|---|---|---|
| Adaptation Speed | 29 Seconds | Minutes/Hours (Fine-tuning) | Days/Weeks (Training) |
| Learning Method | Inference-time Imitation | Offline Fine-tuning | Large-scale Imitation Learning |
| Open Source | Yes | Partial | No |
| Primary Focus | Rapid Skill Acquisition | Vision-Language-Action | General Purpose Autonomy |
Technical Deep Dive
- Architecture: Employs a Vision-Language-Action (VLA) backbone integrated with a temporal attention mechanism to process the 29-second video input.
- Inference Mechanism: Uses a latent space projection to map human demonstrations to the robot's kinematic constraints, bypassing the need for traditional inverse kinematics.
- Data Processing: Implements a frame-sampling strategy that extracts key poses from the demonstration video to generate a trajectory plan.
- Hardware Compatibility: Designed to be hardware-agnostic, supporting various humanoid platforms with different degrees of freedom (DoF) through a modular abstraction layer.
Future ImplicationsAI analysis grounded in cited sources
Timeline
- 2025-06X Square Robot founded with a focus on embodied AI and humanoid control systems.
- 2026-02Initial development of the HOST framework begins, focusing on cross-embodiment imitation.
- 2026-08X Square Robot officially open-sources the HOST framework to the research community.
Weekly AI Recap
Read this week's curated digest of top AI events →
Related Updates
AI-curated news aggregator. All content rights belong to original publishers.
Original source: Pandaily ↗
This is a summary, not the original. Read the source, or get the weekly briefing.
The weekly digest
One email a week. Unsubscribe anytime.